 REPRESENTATIVE CONCEPT
Planned
Battery Coding / Marking Machine
Automation & Material HandlingBattery identification and coding.
AMB-MRK-01Explore equipment ↗
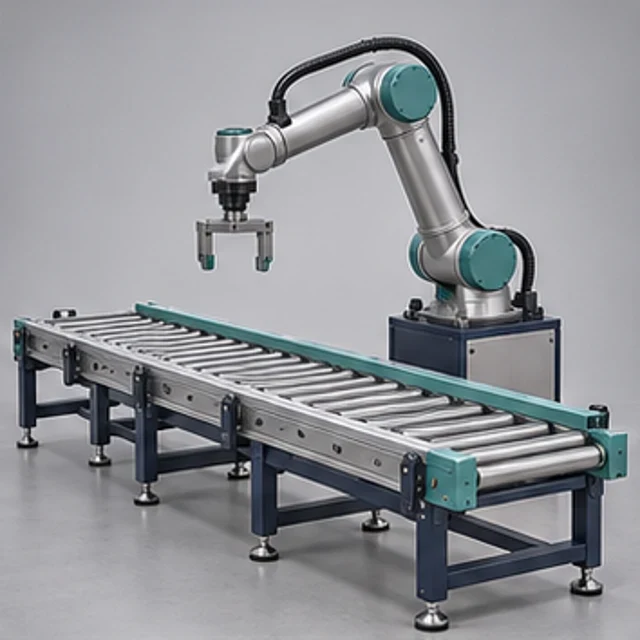
Intended to assess a robot application around a defined part and process, with end-effector, safety system and station interfaces treated as integral scope.
| Technical Parameter | Indicative Configuration |
|---|---|
| Application | Handling / machine tending / assisted assembly / guarded process automation |
| Robot type | Selected industrial robot architecture |
| Number of axes | Selected robot axis count; no universal configuration |
| Payload | Manufacturer-rated payload checked with tool mass, inertia and process loads |
| Reach | Selected model reach checked against cell layout |
| Mounting arrangement | Floor, pedestal or other manufacturer-approved arrangement |
| Robot brand/model selection | Selected model confirmed after application and sourcing review |
| Gripper principle | Mechanical / pneumatic / vacuum grip matched to part |
| Tool mass | Tool mass (kg), centre of gravity and inertia included in load assessment |
| Product envelope | Customer-defined part dimensions (mm) and mass (kg) |
| Cycle-time basis | Whole-cycle simulation/trials including loading, dwell and recovery |
| Placement requirement | System placement criterion defined separately from robot repeatability |
| Vision guidance, optional | Optional vision guidance with representative-part validation |
| Part feeders, optional | Optional feeder or presentation fixture |
| Machine interfaces | Agreed process signals and supported data interfaces |
| PLC/controller integration | Selected robot controller with optional cell PLC integration |
| Interlocks | Assessed access, process and transfer interlocks |
| Safety fencing | Guarded perimeter/access arrangement selected by risk assessment |
| Applicable stopping/safety functions | Selected stop/safety functions validated at complete-cell level |
| Operator access | Controlled access, setup and recovery modes |
| Programme/recipe management | Authorised programmes and controlled recipe selection |
| HMI | Local interface as needed; HMI optional for cell scope |
| Pneumatic/electrical requirements | Selected controller power and end-effector utilities |
| FAT/SAT scope | Agreed factory/site acceptance with actual tools and samples |
| Robot recovery and maintenance access | Safe recovery, isolation and maintenance access; no assumed collaborative safety |
Technical specifications are indicative and configurable. Final equipment parameters, performance and supply arrangements will be confirmed following application review and engineering evaluation.
Payload and reach require actual selected manufacturer data with tool mass, inertia and application limits. Robot repeatability is not complete-system placement accuracy. Collaborative operation is not assumed and needs formal application assessment.
Application-specific solutions combine mechanical engineering and automation integration with selected specialist subsystems. The proposed solution families are Robot handling and machine tending; Robot-assisted assembly; Custom guarded process automation. Configuration, acceptance and supply feasibility are established for the enquiry; this listing does not establish completed models or current stock.
Battery component handling, assisted machine loading and feasibility review of specified assembly tasks. Confirm the intended process, materials and acceptance method during application review.
Mechanical interfaces, operating mode and control requirements are defined during engineering review. Available configuration choices depend on the agreed equipment scope.
Payload and reach require actual selected manufacturer data with tool mass, inertia and application limits. Robot repeatability is not complete-system placement accuracy. Collaborative operation is not assumed and needs formal application assessment.
Power, communications and any compressed-air requirements depend on the selected components and agreed site interfaces. Utilities and installation responsibilities are confirmed during technical review; optional modules are not standard inclusions.
Programming; safety; ROI justification. Payload and reach require actual selected manufacturer data with tool mass, inertia and application limits. Robot repeatability is not complete-system placement accuracy. Collaborative operation is not assumed and needs formal application assessment. Application-specific risk assessment, safeguards and acceptance validation are required before operation.
A documented risk assessment, guarding review, material compatibility check and application-specific operating procedure are required before use. No CE, UL, IEC, hazardous-area approval or other certification is established by this listing. Conformity documentation depends on the agreed scope and destination requirements.
Read the Product Information Disclaimer
Request technical documentation and an application-specific configuration with your enquiry.
This listing represents an intended equipment or engineering offering. Feasibility, configuration and availability require confirmation. Please request the current engineering and supply status.
Share your materials, required capacity, process constraints and acceptance criteria. The team will review feasibility before confirming any custom scope.
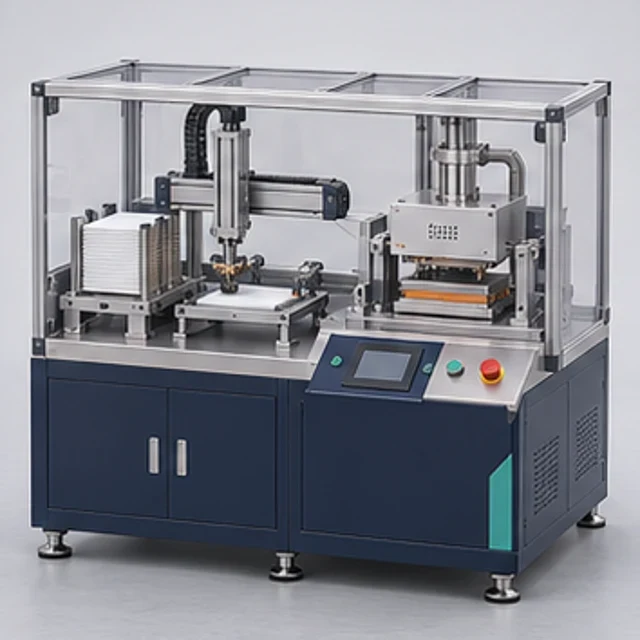
REPRESENTATIVE CONCEPTBattery identification and coding.
 REPRESENTATIVE CONCEPT
Electrode-roll transfer and positioning.
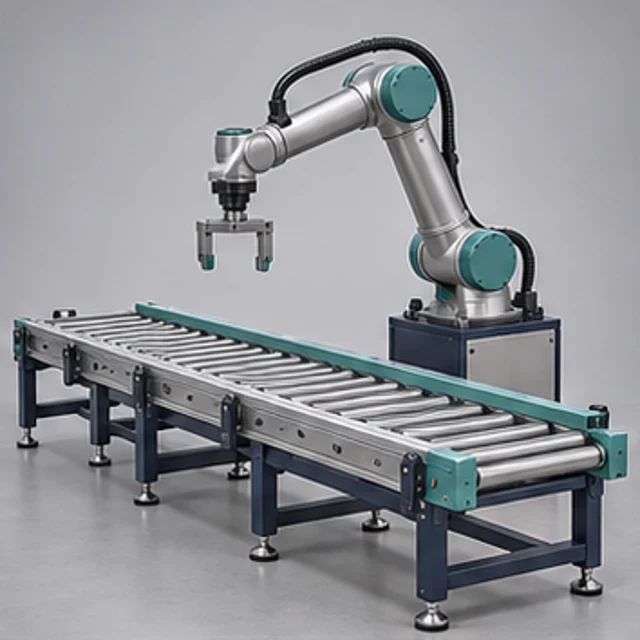
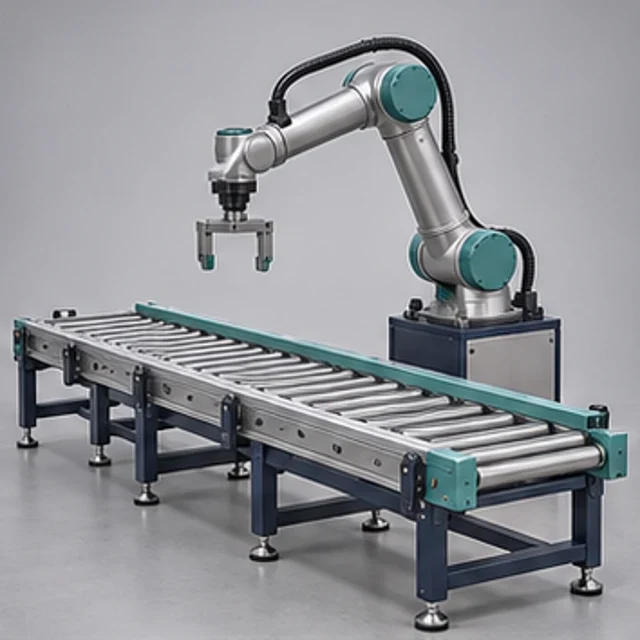 REPRESENTATIVE CONCEPT
Battery-process conveyor handling.